Mechanical Grippers
The most common type of robot gripper, using fingers or jaws to physically grasp objects. Includes parallel grippers, angular grippers, and multi-finger configurations for diverse part geometries.

Discover the complete range of robot end effectors for industrial automation. From mechanical grippers to vacuum systems, find the right tooling solution for your material handling, assembly, and finishing applications.
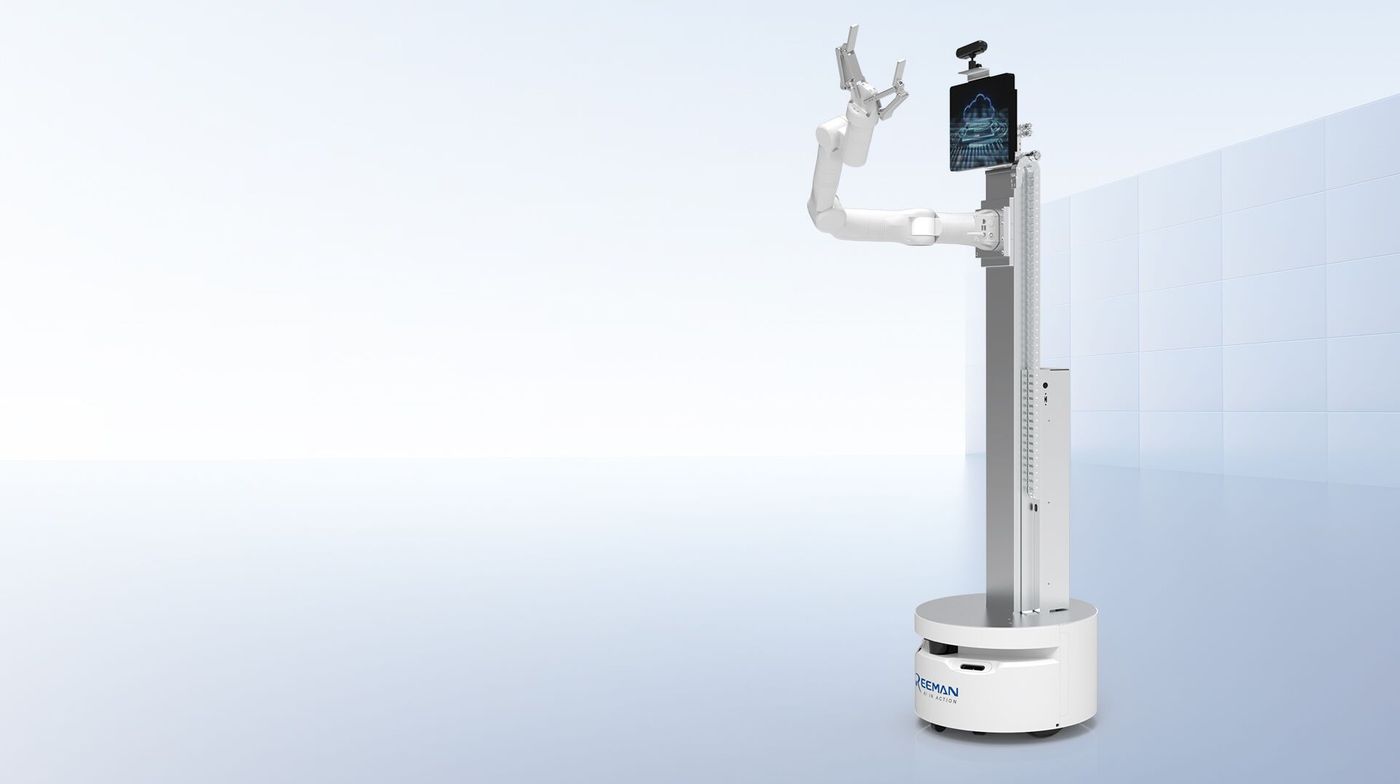
Robot end effectors are the tools that turn a robot arm or AMR into a productive workstation. This guide compares the most common gripping technologies and shows how Reeman mobile robots integrate them for warehouse and factory automation.
A robot end effector is the specialized device attached to the end of a robotic arm that interacts directly with workpieces, tools, or the environment. Also known as End-of-Arm Tooling (EOAT), end effectors transform a general-purpose robot into a task-specific automation solution.
End effectors are the critical interface between the robot and your application. Whether you need to grip, lift, weld, paint, or inspect, selecting the right end effector determines the success of your automation project. Modern end effectors range from simple pneumatic grippers to sophisticated adaptive systems with force feedback and machine vision integration.
At Reeman, we understand that end effector selection directly impacts cycle time, part quality, and operational flexibility. Our AMR platforms and autonomous forklifts are designed to seamlessly integrate with various end effector technologies, enabling complete automation workflows from material transport to precision handling. Learn how end effectors mount to AMR chassis in warehouses.
Modern grippers offer millimeter-level positioning accuracy for delicate handling tasks.
Advanced force feedback prevents damage to fragile parts during handling operations.
Tool changer systems enable robots to switch end effectors automatically for multi-task operations.
Standard ISO mounting patterns ensure compatibility across robot brands and models.
Explore the complete spectrum of robot end effector technologies. Each category offers unique advantages for specific applications, materials, and operational requirements.
The most common type of robot gripper, using fingers or jaws to physically grasp objects. Includes parallel grippers, angular grippers, and multi-finger configurations for diverse part geometries.
Use suction cups and vacuum pressure to lift flat, smooth surfaces. Ideal for handling sheet metal, glass, plastic panels, and packaging materials without mechanical contact forces.
Designed for ferrous metal handling in stamping, coil processing, and sheet metal applications. Available in permanent magnet and electromagnet variants with different control characteristics.
Servo-controlled grippers offering programmable force, position, and speed control. Feature integrated force feedback and precise motion profiles for delicate or precision assembly operations.
Compliant grippers using flexible materials and bio-inspired designs to handle delicate, irregular, or variable objects. Ideal for food handling, soft packaging, and mixed-SKU applications.
Air-powered grippers offering high speed and gripping force at a lower cost. Widely used in high-volume manufacturing where compressed air is readily available and simple on/off control suffices.
Custom tooling for specific manufacturing processes including polishing, deburring, grinding, welding, and inspection. Often feature compliant elements or force control for surface finishing operations.
Get the comprehensive overview of all gripper types, selection criteria, and application guidelines in one detailed resource.
Read Complete GuideCompare the three most common industrial gripping technologies side by side. Use this overview to narrow down the best fit for your parts, cycle speed, and integration constraints.
| Feature | Mechanical | Vacuum | Magnetic |
|---|---|---|---|
| Working principle | Fingers or jaws physically grasp the part | Suction cups lift using negative air pressure | Permanent or electro magnets hold ferrous parts |
| Best materials | Rigid parts: metal, plastic, composites | Flat, smooth, non-porous surfaces | Ferrous metals: steel, iron sheets |
| Typical payload | 0.1 kg – 500+ kg depending on gripper size | 0.05 kg – 200 kg based on cup area & vacuum | 1 kg – 1,000+ kg for heavy sheet metal |
| Surface requirements | Features or edges to grip; tolerant of texture | Requires flat, sealed surface; leakage limits hold | Clean, flat ferrous surface for best contact |
| Cycle speed | Moderate to fast; depends on actuator | Fast pick and place; no jaw motion | Instant engage/disengage for electromagnets |
| Precision | High; fingers can center and orient parts | Moderate; good for consistent flat surfaces | Moderate; fixed pole geometry |
| Maintenance | Periodic lubrication and finger inspection | Cup wear and filter cleaning | Low; check magnet surface and power contacts |
| Typical cost | Low to moderate | Low to moderate | Moderate to high |
Choosing the right end effector requires careful analysis of your application requirements. Follow this systematic approach to identify the optimal solution.
Consider size, shape, weight, surface texture, and material properties. Flat surfaces favor vacuum grippers; irregular shapes may need adaptive or mechanical solutions.
Evaluate required pick/place speed, precision tolerances, and force sensitivity. High-speed operations may favor pneumatic; precision tasks need electric grippers.
Consider temperature, cleanliness requirements, and available utilities. Some applications require food-grade materials or explosion-proof designs.
Ensure compatibility with your robot model, control architecture, and existing tooling systems. Consider power and control signal requirements.
Use our comprehensive selection matrix that matches part geometries and application requirements to the optimal end effector technology.
Our autonomous mobile robots and forklifts are engineered for seamless integration with industry-standard end effector technologies, enabling complete automation from transport to handling.
Reeman's mobile robotics platforms feature standardized mounting interfaces and open SDK architecture, enabling rapid deployment of custom end effector solutions. From material transport to precision placement, our robots work seamlessly with your existing tooling investments.
Standard mechanical interfaces for quick tool changer integration
Full programmatic control of end effector actuation and feedback
Onboard air compressor and electrical outputs for diverse gripper types
Real-time sensor integration for delicate handling operations
Quick answers to common questions about robot end effector load limits, compatibility, and customization.
Payload capacity depends on the end effector technology and size. Mechanical grippers commonly handle 0.1 kg to 500+ kg, vacuum grippers range from 0.05 kg to around 200 kg depending on cup area and vacuum level, and magnetic grippers can lift 1 kg to over 1,000 kg of ferrous sheet metal. Always confirm the rated load with the manufacturer and include a safety factor for dynamic operation.
Reeman mobile robots and autonomous forklifts support ISO 9409-1 mounting patterns and provide an open SDK and API, so they integrate with most industrial robot arms, grippers, and AMR chassis. Our engineering team can verify compatibility with your specific robot brand, controller, and communication protocol before deployment.
Yes. Reeman supports custom mechanical fingers, vacuum suction arrays, and magnetic pole configurations tailored to your part geometry, surface finish, and cycle requirements. We can also adapt mounting plates, power supplies, and control interfaces to match your existing AMR or robot arm.
Not sure which end effector technology is right for your application? Our robotics engineers bring 10+ years of automation experience to help you select and integrate the optimal gripping solution. Contact our team directly for a quick response.
Detailed review of your part geometry, cycle requirements, and operational constraints.
Unbiased guidance on gripper types, suppliers, and integration approaches.
Complete implementation assistance from specification to deployment.
Ongoing assistance throughout your automation journey.
Fill out the form below and our specialists will contact you within 24 hours.
Dive deeper into end effector technologies with our comprehensive library of technical guides, selection criteria, and implementation best practices.
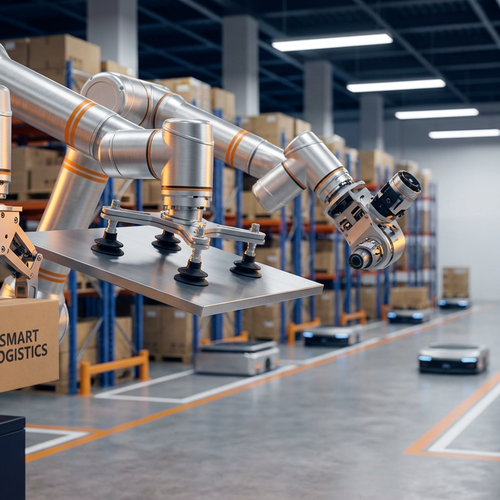
The definitive resource covering all end effector types, applications, and selection methodologies for industrial automation.
Read Guide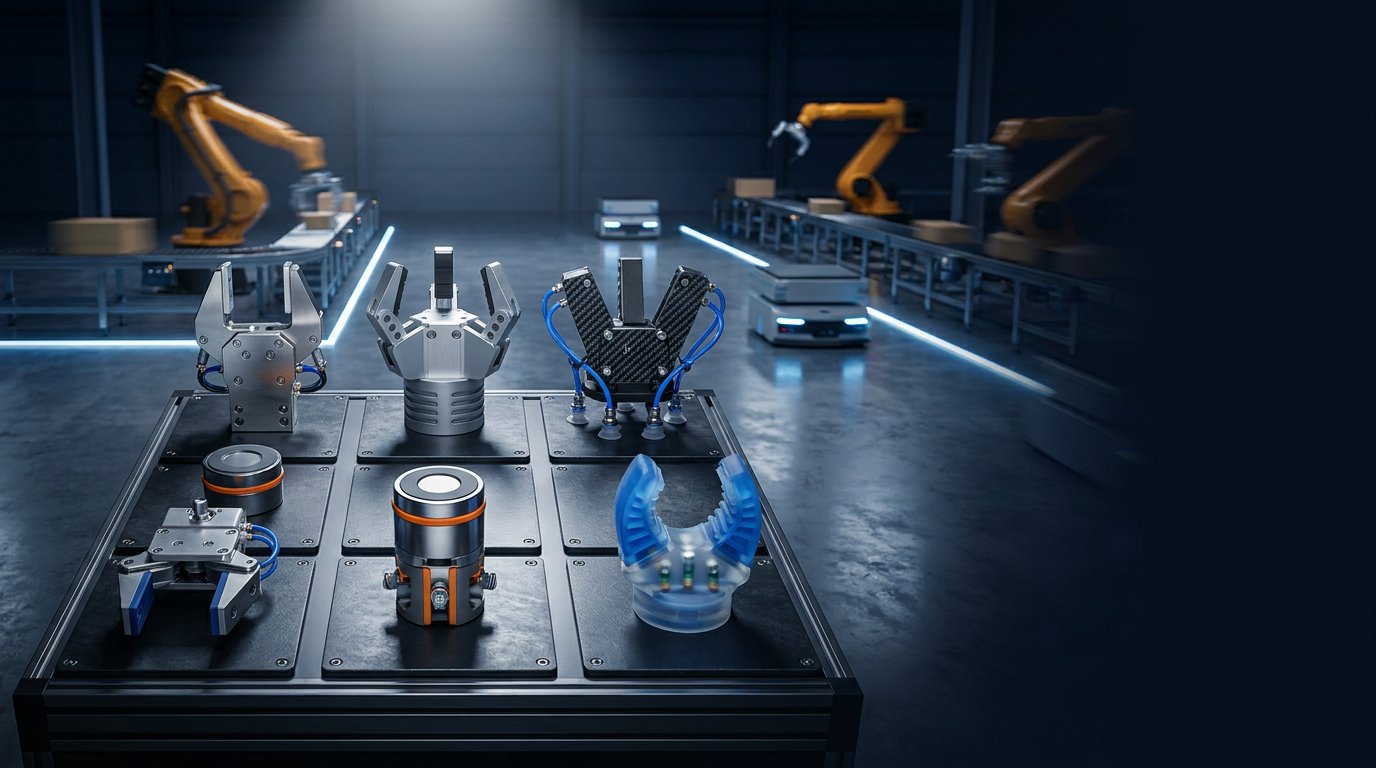
Use our systematic selection matrix to match your part characteristics with the optimal gripper technology.
View Matrix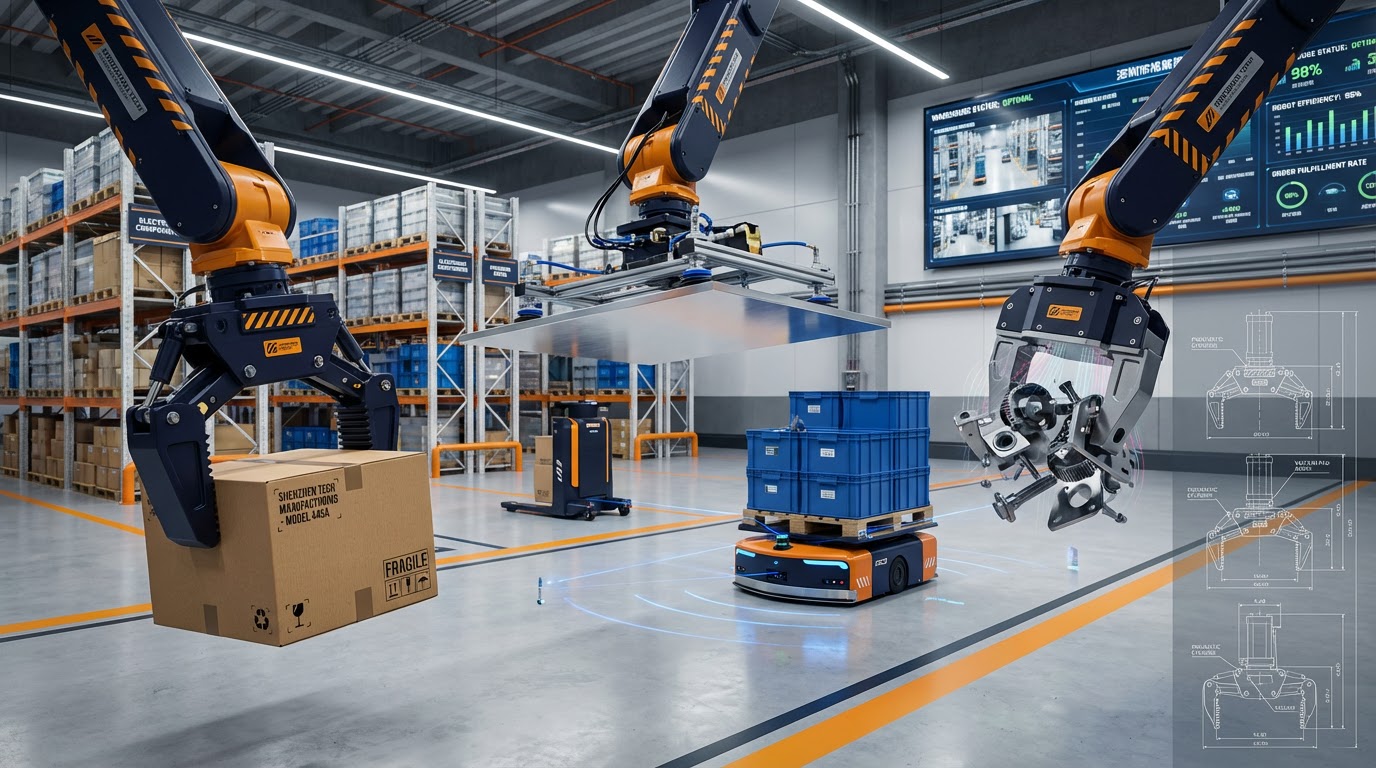
Master the fundamentals of gripper technology with this comprehensive introduction to industrial automation tooling.
Learn More